Product Matrix
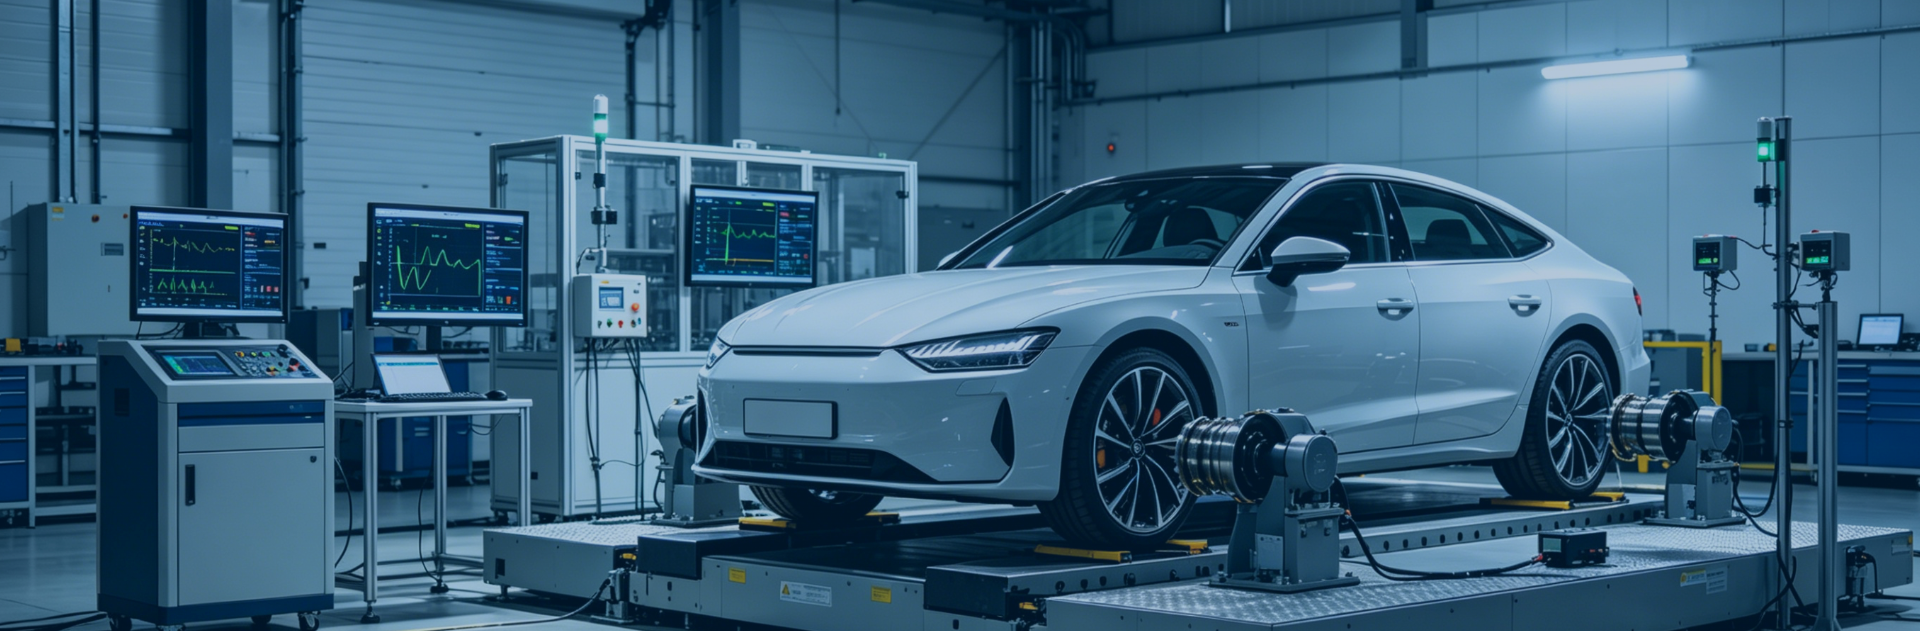
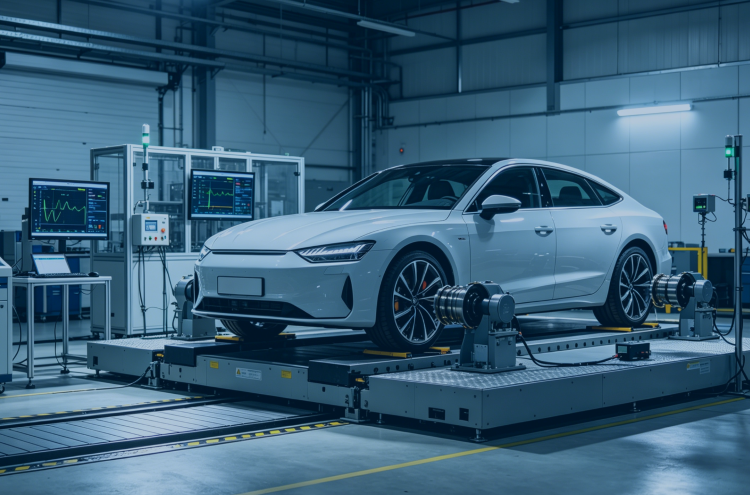
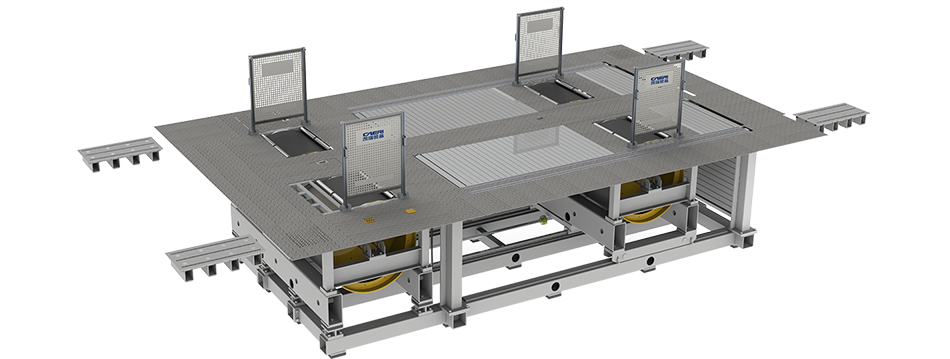
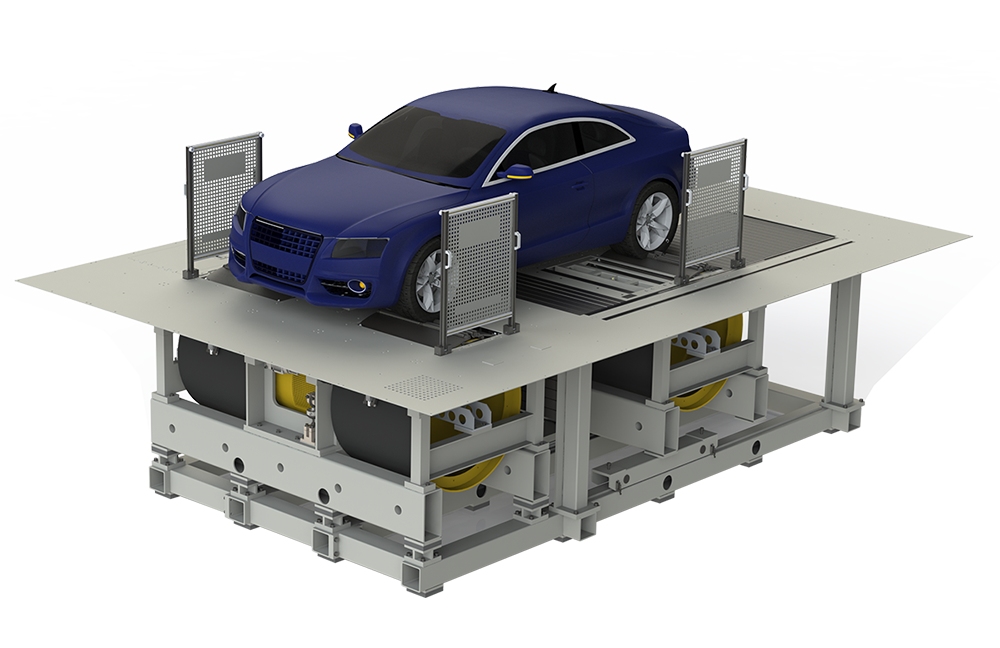
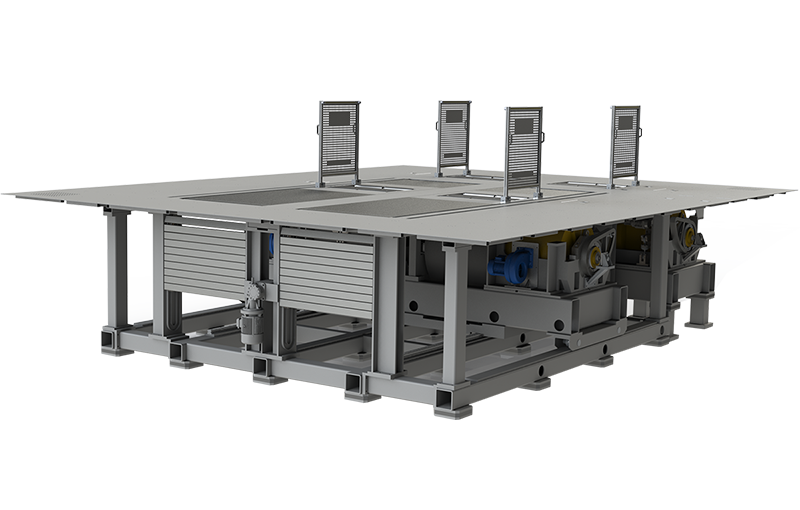
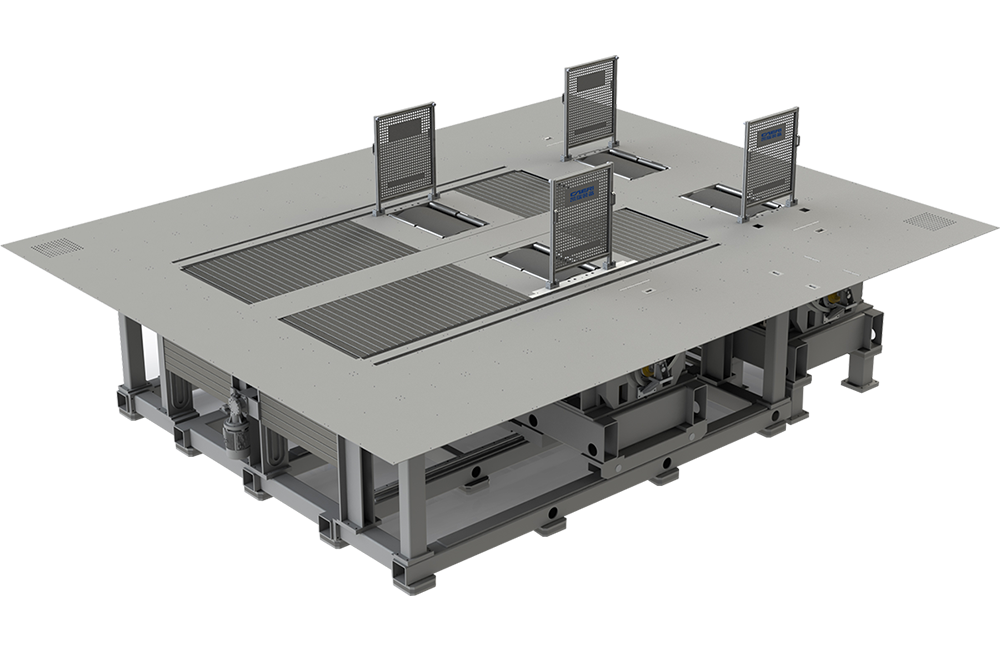
The Karry chassis dynamometer simulates road driving conditions and can test various key performance indicators of vehicles in an indoor environment, such as vehicle power, fuel economy (fuel consumption), multi-condition emissions, electric vehicle range, and engine cooling and heat dissipation capacity of the entire vehicle. It can also conduct tests like continuous climbing of steep slopes and hills (1-8%), and constant-speed continuous downhill driving simulation (1-8%) (for models 11 and I1A). It is widely used in industries such as automotive manufacturing, automotive inspection and maintenance, and environmental protection.
It uses rollers to simulate the road surface. By controlling the test conditions, the influence of the surrounding environment is minimized. At the same time, through the power absorption loading device, it simulates the driving resistance of the vehicle and controls the driving conditions, conducting complex cycle tests that are in line with reality with high repetition accuracy. After equipping with an environmental chamber, it can also conduct relevant vehicle performance tests (such as high-temperature and low-temperature tests) under different environmental conditions.
 Main advantages

High reliability and low maintenance structural system design
80,000 hours of quality guarantee
Wide temperature system design

The accuracy meets the requirements of the EPA.

Patented road simulation and electric inertia control loading
A controller with completely independent intellectual property rights
More flexible function configuration and solutions
A design that is more in line with domestic usage habits

With the design of self-aligning bearings, the service life of the bearings is significantly prolonged.
Reduce the waiting time of thermal machines
Reduce the lag in force measurement

The price advantage is obvious and the economic performance is outstanding.
Low maintenance costs

Integration of power supply, consumption and electricity usage testing system
Can be equipped with throttle actuators or autopilots
Enhanced Road Condition Data Collection
Performance indicators| Project | Light-duty two-wheel drive chassis dynamometer | Light-duty four-wheel drive chassis dynamometer | |||||||||||
| Single-motor two-wheel drive | Two-motor two-wheel drive | Dual-motor four-wheel drive | Four-motor four-wheel drive | ||||||||||
| 150KW | 200KW | 220KW | 150KW×2 | 200KW×2 | 220KW×2 | 150KW×2 | 200KW×2 | 220KW×2 | 150KW×4 | 200KW×4 | 220KW×4 | ||
| Motor power | 150KW | 200KW | 220KW | 150KW×2 | 200KW×2 | 220KW×2 | 150KW×2 | 200KW×2 | 220KW×2 | 150KW×4 | 200KW×4 | 220KW×4 | |
| Rated traction force | 5400N | 7200N | 7900N | 5400N×2 | 7200N×2 | 7900N×2 | 5400N×2 | 7200N×2 | 7900N×2 | 5400N×4 | 7200N×4 | 7900N×4 | |
| Maximum traction | 8100N | 10000N | 11000N | 8100N×2 | 10000N×2 | 11000N×2 | 8100N×2 | 10000N×2 | 11000N×2 | 8100N×4 | 10000N×4 | 11000N×4 | |
| Traction measurement accuracy | ±0.1%F.S | ±0.1%F.S | ±0.1%F.S | ±0.1%F.S | |||||||||
| Traction control accuracy | ±0.2%F.S | ±0.2%F.S | ±0.2%F.S | ±0.2%F.S | |||||||||
| Maximum speed | 250km/h | 250km/h | 250km/h | 250km/h | |||||||||
| Speed measurement accuracy | <±0.02km/h | <±0.02km/h | <±0.02km/h | <±0.02km/h | |||||||||
| Speed control accuracy | <±0.05km/h | <±0.05km/h | <±0.05km/h | <±0.05km/h | |||||||||
| Accuracy of acceleration measurement | <±1%Or±0.005m/s2 Take the maximum value | <±1%Or±0.005m/s², Take the maximum value | <±1%Or±0.005m/s², Take the maximum value | <±1%Or±0.005m/s2, Take the maximum value | |||||||||
| Inertia simulation range | 450kg~3500kg | 450kg~5500kg |
Two-wheel drive:450kg~3500kg Four-wheel drive:450kg~5500kg |
Two-wheel drive:450kg~3500kg Four-wheel drive:450kg~5500kg |
|||||||||
| 450kg~4500kg | Two-wheel drive:450kg~4500kg Four-wheel drive:450kg~5500kg |
Two-wheel drive:450kg~4500kg Four-wheel drive:450kg~5500kg |
|||||||||||
| 450kg~5000kg | Two-wheel drive:450kg~5000kg Four-wheel drive:450kg~5500kg |
Two-wheel drive:450kg~5000kg Four-wheel drive:450kg~5500kg |
|||||||||||
| Road simulation accuracy | ±1% calculated value or 9.8N, take the larger value | ±1% calculated value or 9.8N, take the larger value | ±1% calculated value or 9.8N, take the larger value | ±1% calculated value or 9.8N, take the larger value | |||||||||
| System response time | 100ms | 100ms | 100ms | 100ms | |||||||||
Other key technical indicators| Project | Heavy-duty two-wheel drive chassis dynamometer | ||
| Type | Single-motor two-wheel drive | Two-motor two-wheel drive | |
| Motor power | 560KW | 560KW×2 | 700KW×2 |
| Rated traction force | 40000N | 40000N×2 | 50000N×2 |
| Maximum traction | 52000N | 52000N×2 | 60000N×2 |
| Traction measurement accuracy | ±0.1%F.S | ||
| Traction control accuracy | ±0.2%F.S | ||
| Maximum speed | 160km/h | ||
| Speed measurement accuracy | <±0.02km/h | ||
| Speed control accuracy | <±0.05km/h | ||
| Accuracy of acceleration measurement | <±1%Or±0.005m/s²,Take the maximum value | ||
| Inertia simulation range | 3500kg~30000kg | 3500kg~49000kg | 3500kg~55000kg |
| Road simulation accuracy | ±1% calculated value or 9.8N, take the larger value | ||
| System response time | 100ms | ||
Optional system